

SH31001P12F2000
Description
Description
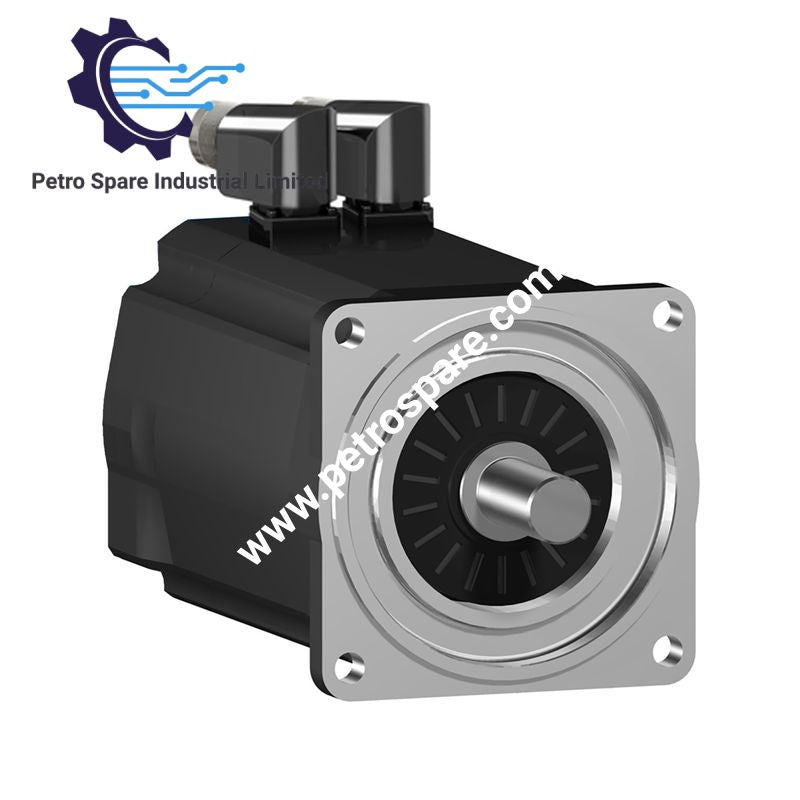
Configured for rotary motion and encoder feedback in PacDrive 3 motion systems, the Schneider Electric SH31001P12F2000 (SH31001P SH3 servo motor) provides three-phase electromechanical output with a parallel key shaft, holding brake, and absolute multiturn SinCos Hiperface encoder.
Hardware Specifications
| Parameter | Specification |
|---|---|
| Model | SH31001P12F2000 |
| Base Model | SH31001P |
| Brand | Schneider Electric |
| Product Type | Servo Motor |
| Range | Lexium 52 & Motors |
| System Compatibility | PacDrive 3 |
| Origin | DE |
| Weight | 4.8 kg |
| Dimensions | 199.5 mm length; 95 mm centering collar diameter; 3.5 mm centering collar depth |
| Operating Temp | Not specified in supplied data |
| Power Consumption | Continuous power: 1190 W |
| Maximum Mechanical Speed | 6000 rpm |
| Rated Supply Voltage | 115...480 V |
| Phase | Three phase |
| Continuous Stall Current | 3.5 A |
| Continuous Stall Torque | 2.94 N.m |
| Peak Stall Torque | 9.6 N.m |
| Maximum Current Irms | 12.0 A |
| Nominal Output Power | 410 W at 115 V single phase; 790 W at 230 V single phase; 1410 W at 400 V three phase; 1630 W at 480 V three phase |
| Nominal Speed | 1250 rpm at 115 V; 2500 rpm at 230 V; 5000 rpm at 400 V; 6000 rpm at 480 V |
| Nominal Torque | 2.91 N.m at 115 V; 2.64 N.m at 230 V; 2.27 N.m at 400 V; 2.27 N.m at 480 V |
| Shaft End | Parallel key |
| Shaft Diameter | 19 mm |
| Shaft Length | 40 mm |
| Key Width | 6 mm |
| Encoder Type | Absolute multiturn SinCos Hiperface |
| Speed Feedback Resolution | 128 periods |
| Holding Brake | Yes |
| Holding Torque | 9 N.m |
| Mounting | International standard flange |
| Motor Flange Size | 100 mm |
| Electrical Connection | Rotatable right angled connector |
| IP Protection | IP54 shaft bushing without shaft seal ring; IP65 motor; IP65 shaft bushing |
| Cooling | Natural convection |
| Rotor Inertia | 2.018 kg.cm2 |
| Stator Resistance | 3.8 Ohm |
| Stator Inductance | 9.5 mH |
| Motor Poles | 4 |
| Maximum Radial Force | 900 N at 1000 rpm; 720 N at 2000 rpm; 630 N at 3000 rpm; 570 N at 4000 rpm; 530 N at 5000 rpm |
| Maximum Axial Force | 160 N |
| Mounting Holes | 4 holes, 9.0 mm diameter, 115 mm mounting circle |
| Torque Constant | 0.84 N.m/A at 120 deg C |
| Back EMF Constant | 60 V/krpm at 20 deg C |
| Copper Hot Temperature | 130 deg C |
| GTIN | 3606485296586 |
Servo Motor and Encoder Characteristics
The SH3 motor uses a four-pole electromagnetic assembly with natural-convection cooling and a keyed 19 mm diameter shaft. Motion feedback is provided by an absolute multiturn SinCos Hiperface encoder with 128-period speed feedback resolution. The integrated holding brake provides 9 N.m holding torque.
The motor provides a maximum mechanical speed of 6000 rpm and a peak stall torque of 9.6 N.m. Mechanical load limits are specified separately for radial and axial forces. The maximum radial force varies with shaft speed and reaches 530 N at 5000 rpm. The electrical interface uses rotatable right angled connectors.
For Schneider Electric motion control installations, encoder feedback compatibility, motor sizing data, and drive configuration must correspond to the SH31001P motor reference. The supplied data identifies PacDrive 3 as the compatible motion system and SH31001P as the sizing reference.
Frequently Asked Questions
Q: What encoder is integrated into the SH31001P12F2000?
A: The motor has an absolute multiturn SinCos Hiperface encoder with 128 periods of speed feedback resolution.
Q: What mechanical shaft configuration is provided?
A: The motor has a 19 mm diameter, 40 mm long parallel key shaft with a 6 mm key width.
Q: Does the motor include a holding brake?
A: Yes. The integrated holding brake has a specified holding torque of 9 N.m.
Field Installation Guidelines
- Mount the motor using the specified 100 mm international standard flange and four mounting holes.
- Verify shaft alignment before coupling the driven mechanism to the parallel key shaft.
- Keep the radial and axial shaft loads within the specified force limits for the actual operating speed.
- Connect the motor using the specified rotatable right angled electrical connectors.
- Route motor power and encoder wiring separately where practical to reduce electrical interference.
- Connect cable shields according to the drive and machine grounding scheme.
- Confirm encoder wiring and Hiperface interface compatibility before commissioning.
- Maintain adequate clearance around the motor for natural-convection cooling.
- Verify the required IP protection at the motor and shaft interface after mechanical installation.
- Configure the associated PacDrive 3 motion system using the SH31001P sizing reference and the electrical ratings of the motor.
Product Benefits
Product Benefits
- 100% genuine products in stock with fast delivery. Learn more...
- 30-day return policy for quality assurance. Learn more...
- 12-month warranty for peace of mind. Learn more...
Reviews
Reviews